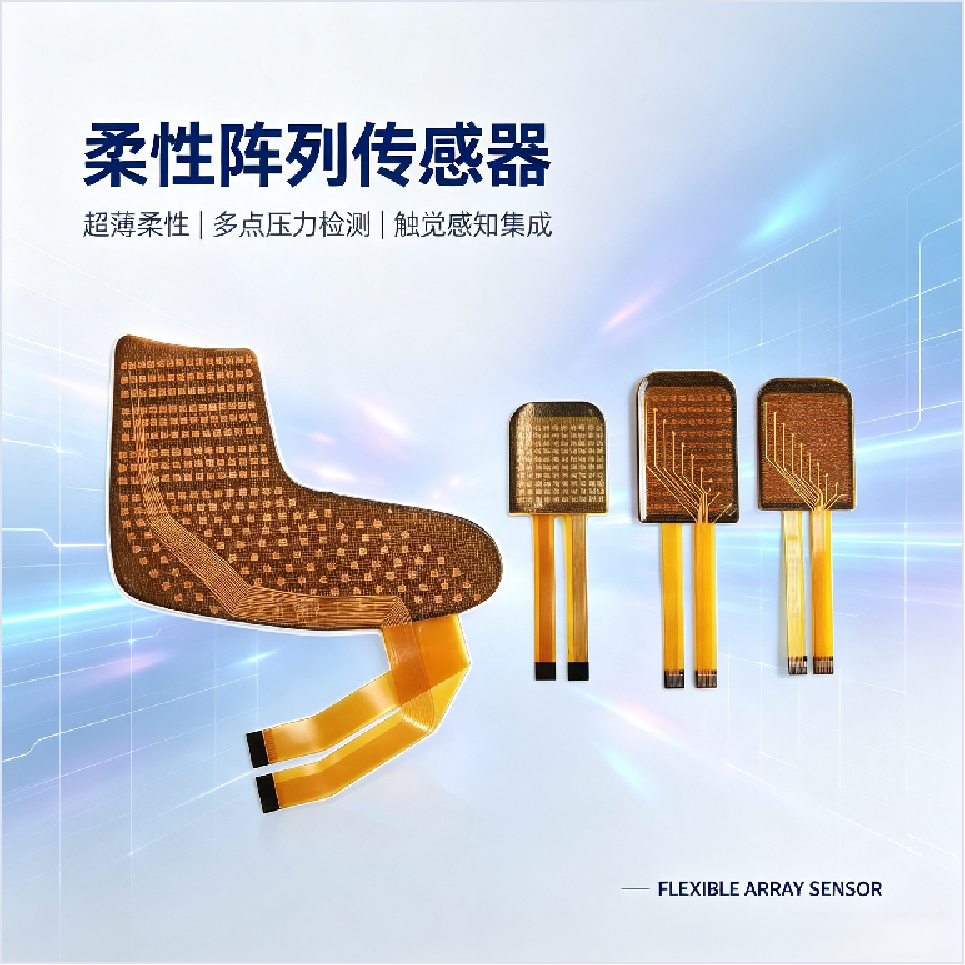
Micron-level flexible array tactile sensor - RXCJ1A-1
- Sensor type Piezoresistive flexible array pressure sensor
- Array density Up to 19×19 pixels (array scale customizable)
- Spatial resolution 1 mm
- Response time < 10 ms
- Sensor thickness From 0.1 mm
- Fatigue life > 1 million mechanical cycles
- Pressure range Wide range (feather-light force → heavy-load grasping)
- Operating temperature range Wide, high and low temperature resistant formulas available
- Protective formula Optional waterproof / dustproof / oil-resistant
- Output form High-resolution tactile heat map (digital signal matrix)
Product Introduction
I. Product Introduction
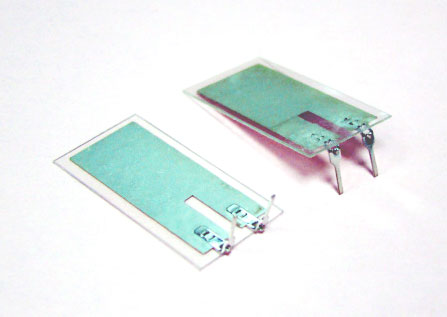
This is an "electronic skin" designed specifically for robots—a conformable, bendable flexible sensing film that can convert pressure distribution on the contact surface into a high-resolution digital signal matrix in real time, giving robotsTactile perception and force feedback capabilities comparable to human fingertips。
In the technological evolution of robots from "seeing" to "touching," this sensor addresses exactlyTactile sensingthis core bottleneck. Whether it is the precise grasping of dexterous hands or the safe interaction of collaborative robotic arms, it relies on this to sense "how much force was used," "what shape was contacted," and "whether slipping occurred."
II. Working principle
1. Physical deformation:External force acts on the surface, causing microscopic deformation of the internal microstructure.
2. Impedance modulation:The contact area or pathway of the sensitive conductive layer changes, causing resistance to change.
3. Signal acquisition:Orthogonal electrode layers precisely capture resistance changes at each pixel.
4. Tactile imaging:Peripheral circuits convert to high-resolution "tactile heat map".
III. Product Features
| Advantage Dimensions | Specific Performance |
|---|---|
| Ultra-high resolution | Up to 19×19 pixel array, spatial resolution up to 1mm, comparable to the texture resolution capability of human fingertips |
| Ultra-fast response | Response time < 10ms, capable of tracking rapid dynamic force changes, suitable for real-time force control scenarios |
| Ultra-thin and flexible | Thickness as low as 0.1mm, can conformally fit complex 3D curved surfaces such as robotic fingers and spheres |
| Ultra-long lifespan | Fatigue life > 1 million mechanical cycles, consistent performance, suitable for long-term industrial use |
| Wide range | From feather-light force perception to heavy-load grasping, covering an extremely wide pressure range |
| Environmental adaptability | Wide operating temperature range, high and low temperature resistant formulas available; optional waterproof, dustproof, oil-resistant materials |
| Flexible customization | Supports dot matrix and custom-shaped mold opening, array scale can be customized on demand |
IV. Core Parameters
| Indicator | |
|---|---|
| Sensor Type | Piezoresistive flexible array pressure sensor |
| Array Density | Up to 19×19 pixels (array scale customizable) |
| Spatial resolution | 1 mm |
| Response time | < 10 ms |
| Sensor Thickness | From 0.1 mm |
| Fatigue life | > 1 million mechanical cycles |
| Pressure Range | Wide range (feather-light force → heavy-load grasping) |
| Operating temperature range | Wide, high and low temperature resistant formulas available |
| Protective formula | Optional waterproof / dustproof / oil-resistant |
| Output form | High-resolution tactile heat map (digital signal matrix) |
V. Product Form
- Flexible array, conforms to curved surfaces: As thin as 0.1mm, can conform to complex curved surfaces such as robotic fingers and spheres, and can still sense stably even when the entire sheet is bent or rolled.
- Multi-spec array: From demonstration level to 19×19 high density, flexibly adapting to different precision requirements.
- Custom shapes: Supports dot matrix and custom-shaped mold opening to meet special structural design needs.
- Plug and play: Standard interface design, easy to quickly integrate into existing robotic systems.
Main Application Areas
- Robotic Dexterous Hands — Enables precise grasping and manipulation by providing real-time tactile feedback for force control and slip detection.
- Collaborative Robots — Ensures safe human-robot interaction by sensing contact forces and preventing excessive pressure during collaborative tasks.
- Prosthetic Limbs — Restores tactile sensation for amputees, allowing them to feel pressure and texture when handling objects.
- Wearable Electronics — Integrates into smart clothing and health monitoring devices for pressure mapping and gesture recognition.
- Industrial Automation — Optimizes assembly and quality control processes by providing high-resolution pressure distribution data for delicate handling.
Keywords:flexible tactile sensor, array pressure sensor, electronic skin, robotic tactile sensing, piezoresistive sensor, high-resolution pressure mapping, force feedback sensor, flexible pressure sensor